English / 简体中文

RP1: An OpenSource Full-Stack Platform for Agentic Humanoids
From mechanical design and electronics to firmware, control and learning.
Built to be understood. Open to be built upon.

Open by Design
RP1 is RoboParty's fully open-source humanoid platform: a shared foundation for building, understanding and extending a real robot.
The platform brings mechanical and electrical design, joint modules, firmware, robot models, deployment and learning into one connected development stack. Explore a single subsystem, reproduce a build, or develop your own control and learning workflows.
| Hardware you can inspect | Software you can extend | Intelligence you can explore |
|---|---|---|
| Mechanical CAD, schematics, PCB layouts, Gerber files, BOM and assembly documentation. | Linux BSP, communication, device interfaces, robot descriptions and deployment modules. | Locomotion training, motion imitation, tracking and behavior-model projects. |
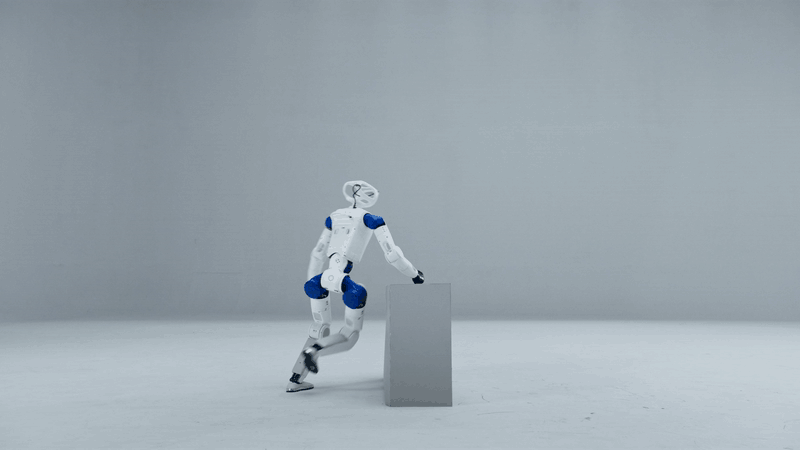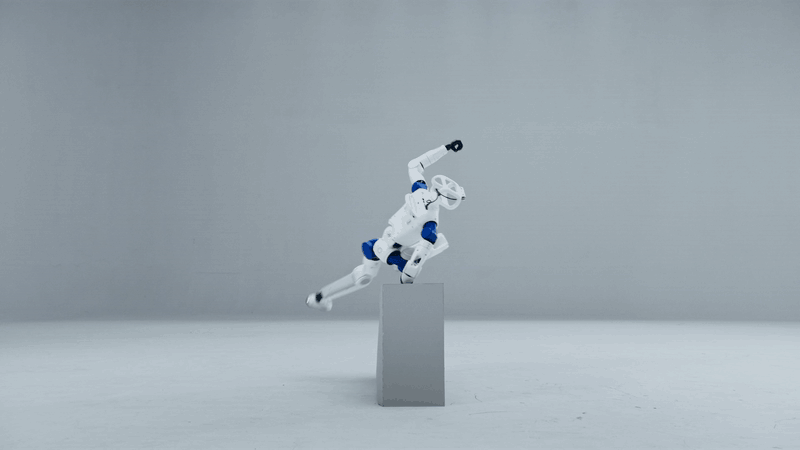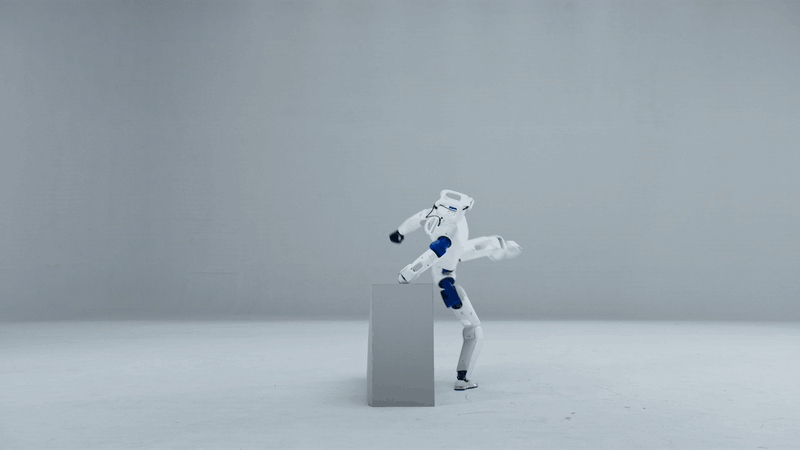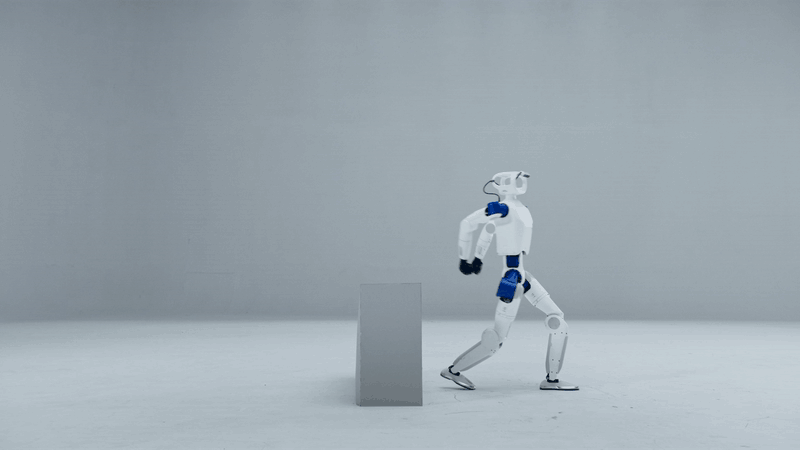
RP1, photographed in the real world.
One Robot. A Connected Stack.
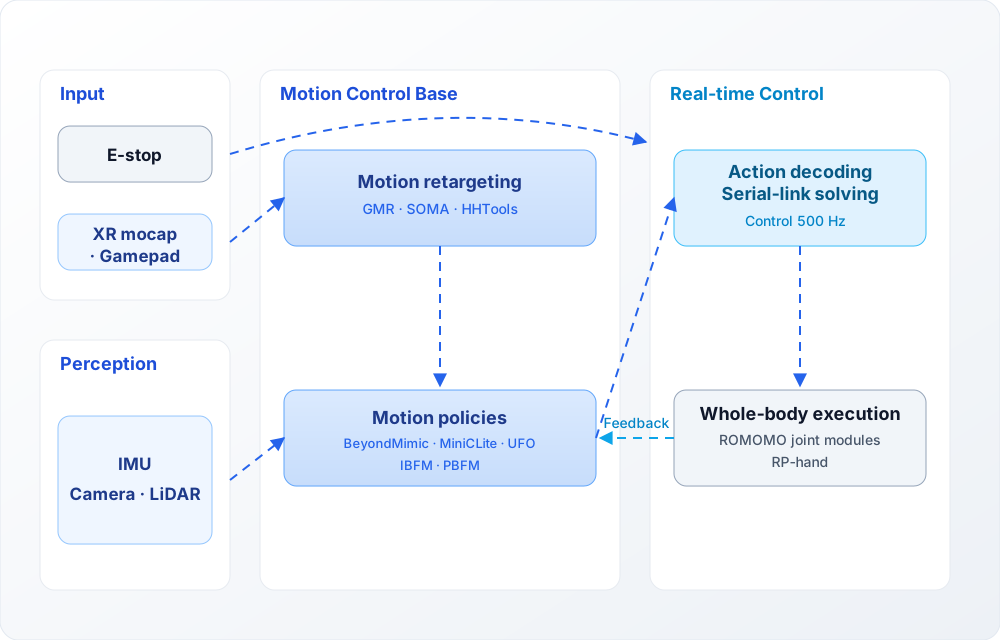
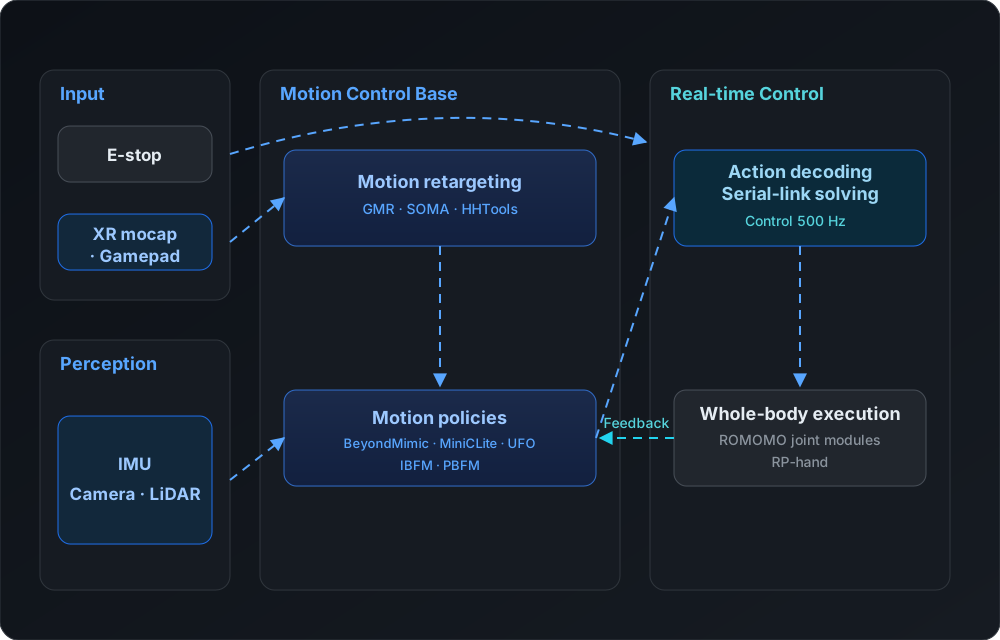
No black boxes, nothing withheld — full control handed back to the developer
Explore the Repositories
Release contents, supported configurations and setup instructions are maintained in each repository.
Contributions belong in the relevant sub-repository. This overview repository does not accept pull requests; please open issues and pull requests in the project you are working on.
Hardware & Tools
| Repository | Description |
|---|---|
| rp1_hardware | Mechanical source files, electronics, testing and assembly SOPs. |
| ROMOMO | Joint modules, firmware and host tools. |
| RP Hand | Dexterous hand product documentation, wiring, companion applications, CAD and robot models. Includes the C++ / Python / ROS 2 SDK entry point. |
| RP1_TEST | RP1 full-machine testing. |
| roboparty_joystick | RoboParty controller and app. |
Robot configurations
See the description repository's current release for supported robot configurations.
Supported configurations include 24, 28, 30 and 42 DoF variants.
Software & Systems
| Repository | Description |
|---|---|
| roboparty_deploy | Deployment framework for RPO and RP1, with easy-to-use SDKs for imu, motor, inference and camera modules, callable from C++ and Python. |
| RP1_description | URDF and MJCF models, 3D meshes, and robot and RP Hand configurations. |
| roboparty_train | Isaac Lab training workspace for RPO locomotion policies, covering AMP, BeyondMimic and Parkour workflows with RSL-RL training and motion retargeting. |
| RP1_firmware | Linux BSP, USB-CAN bridge, low-level SDK and packages. |
Demo
| Project | Description |
|---|---|
| AMP | Learns motion priors from reference motions via adversarial training, enabling natural-looking locomotion and control. |
| BeyondMimic | Reproduces expressive whole-body movements by tracking reference motions, including dance and motion-imitation sequences. |
| Parkour | Learns perceptive locomotion policies to traverse challenging terrain, including stairs, gaps and obstacles. |
| MimicLite | Provides an efficient, general-purpose humanoid motion-tracking system for training deployable PPO and PPO-ROA policies. |
| UFO | Provides a general unsupervised reinforcement learning framework for humanoid control, supporting FB/TeCH training, motion tracking and reward and goal inference. |
| PBFM | Maps motion references, target body states and rewards into a shared behavioral intent space, combining intent with depth perception for terrain-adaptive control. |
| IBFM (RP1 support coming soon) | Learns reward-conditioned robust humanoid interaction via unsupervised reinforcement learning, demonstrated on carry, push and kick box tasks. |
| INTACT-JEPA (RP1 support coming soon) | Learns an intent-to-action mapping with JEPA for goal-conditioned robot control without broad action search. |
Related papers
- P-BFM: Perceptive Behavioral Foundation Models for Humanoid Control via Unsupervised Reinforcement Learning — Xue Wang, Yitang Li, Yiming Zhang, Siqin Wang, Junhan Sun, Zhihao Liu, Yaojie Shen, Jingbo Yuan, Hao Zhao, Qingdu Li. ICLR 2027
- I-BFM: Reward-Conditioned Robust Humanoid Interaction via Unsupervised Reinforcement Learning — Ziqi Han, Yitang Li, Junhan Sun, Fanrong Dong, Yaojie Shen, Lei Ye, Zetong Jing, Yongqi Zhang, Yiming Zhang, Xue Wang, Hao Zhao. ICRA
- PredActor: Predictive Action Diffusion for Steerable Onboard Humanoid Control — Lei Ye, Haibo Gao, Yitang Li, Peng Xu, Zetong Jing, Junhan Sun, Fanrong Dong, Ziqi Han, Xue Wang, Jianhua Sun, Cewu Lu, Hao Zhao, Liang Ding. ICRA
- From Hitter to Player: Separating Motor Execution and Strategy in Competitive Humanoid Table Tennis — Fanrong Dong, Ziyi Sun, Ziqi Han, Junhan Sun, Lei Ye, Zetong Jing, Hao Zhao, Shaoxun Liu, Rongrong Wang. ICRA
- INTACT: Isomorphic Intent-to-Action Learning for Search-Free World Models — Junhan Sun, Hao Zhao, Guofeng Zhang. ICLR
- VIStream: Bringing Inertial Sensing to Streaming Geometric Foundation Models — Mingzhe Liu. ICRA
Built in the Open. Built Together.
Meet the community, share your work, and connect with RoboParty.
The RoboParty Ecosystem
RoboParty
Open hardware. Open intelligence. Shared possibility.
GPL-3.0 · © RoboParty · Back to top
See each sub-repository for its applicable license.