Mechanical Design Handbook
3D Printed Remote Controlled
Weapon System v5
WILDCARD
Table of contents
1. Overview
The RCWS (Remote Controlled Weapon System) v5 prototype is one of several 3D-printed RCWS projects. The goal of this project is to demonstrate an electro-optical fire-control system at a range of approximately 30 meters. The RCWS v5 was designed so that all mechanical parts, except for electronic components and bearings, can be fabricated using an Ender 3 V2 3D printer.
This document presents the mechanical design and assembly of the RCWS v5.
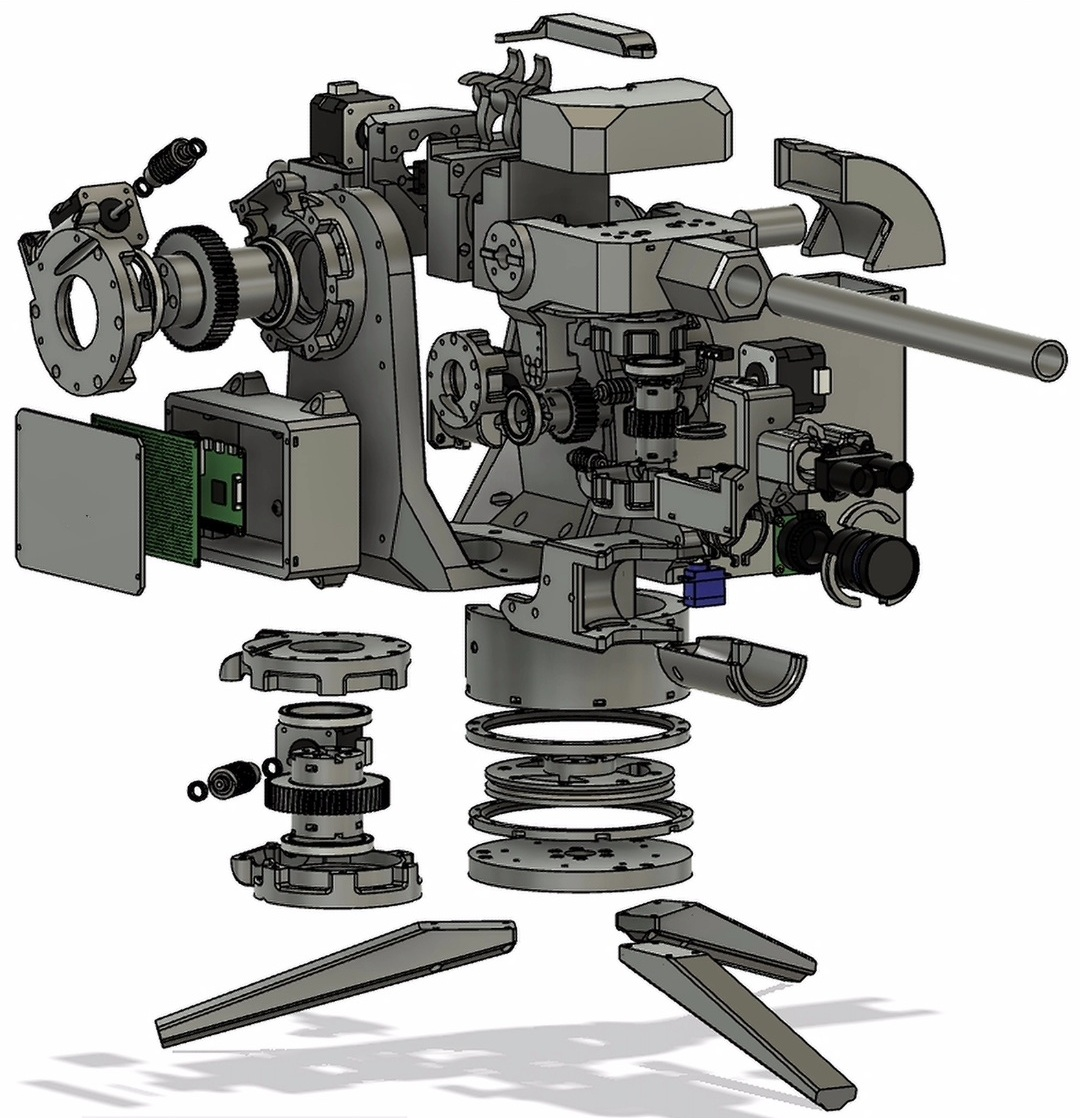
Figure 1.
2. System Architecture
The RCWS v5 consists of four main subsystems: the drive system, launcher, electro-optical targeting system (EOTS), and electronic control system.
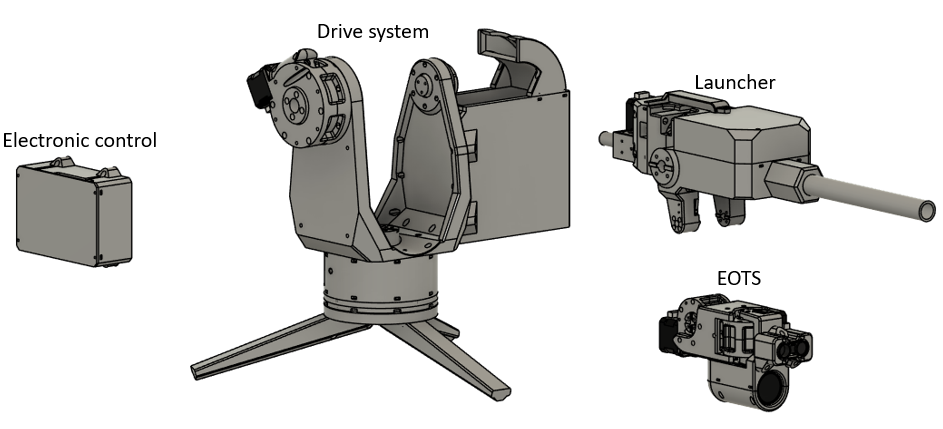
Figure 2.
The drive system and EOTS each use two worm-gear actuators. The launcher and camera can be controlled independently. This four-axis architecture supports fire-control operation against moving targets and at extended ranges.
All mechanical parts of the RCWS v5 are designed to be printable on an Ender 3 V2 3D printer. The largest component, Main Frame (Main_Frame), has a bounding box of 180 × 145 × 248 mm.
3. Drive System
The drive system is a two-axis pan-tilt chassis comprising the main frame, neck frame, two worm-gear actuators, a 3D-printed azimuth bearing, and a tripod.
3-1. Main Frame & Neck Frame
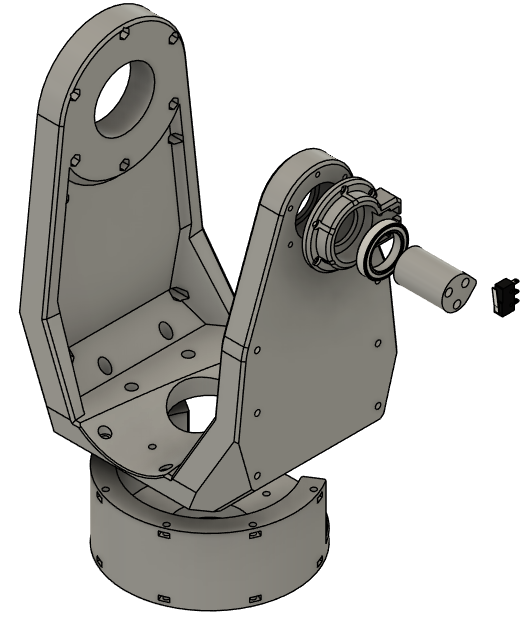
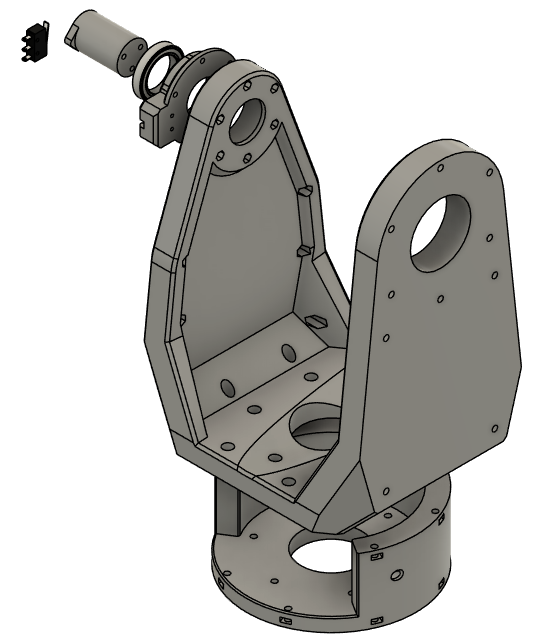
Figure 3.
<Non 3D printed Parts>
M2 x 10mm bolt
M3 x 10mm bolt
M3 x 12mm bolt
M3 hex nut
M4 x 15mm bolt
limit switch
6805ZZ bearing
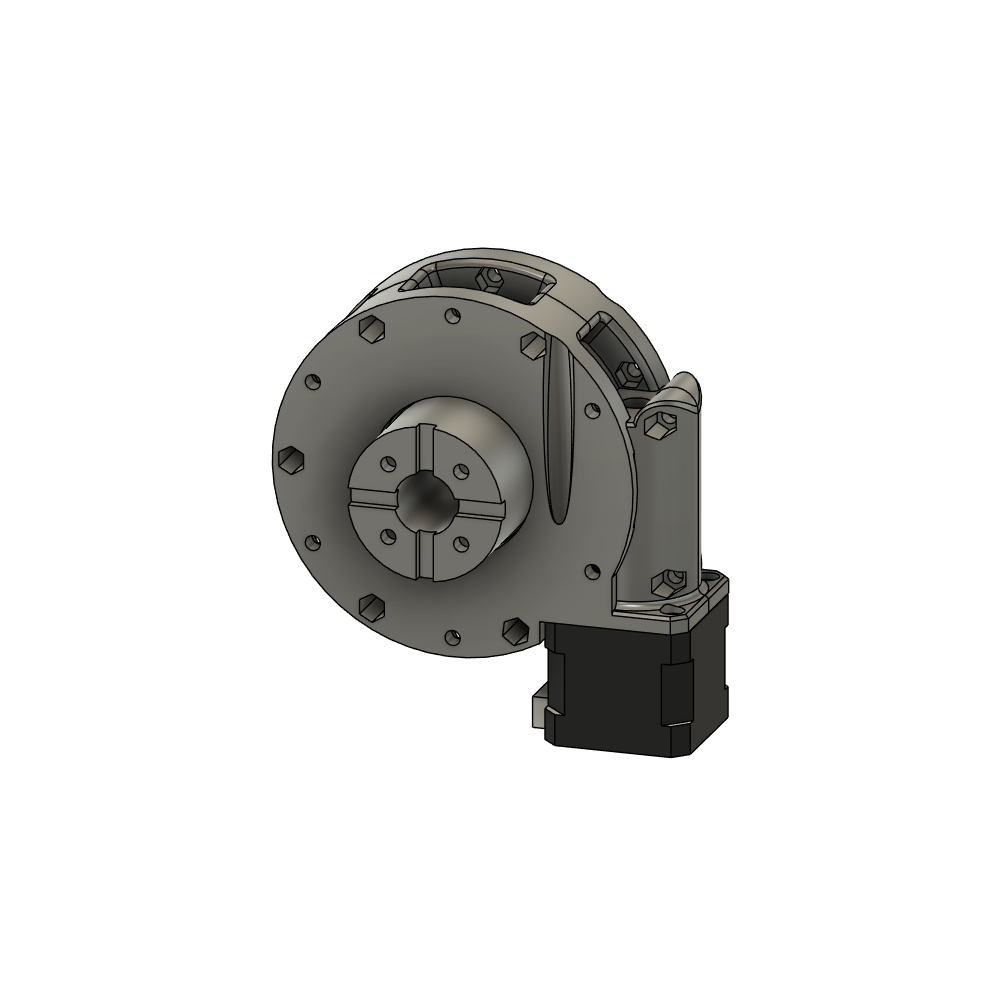
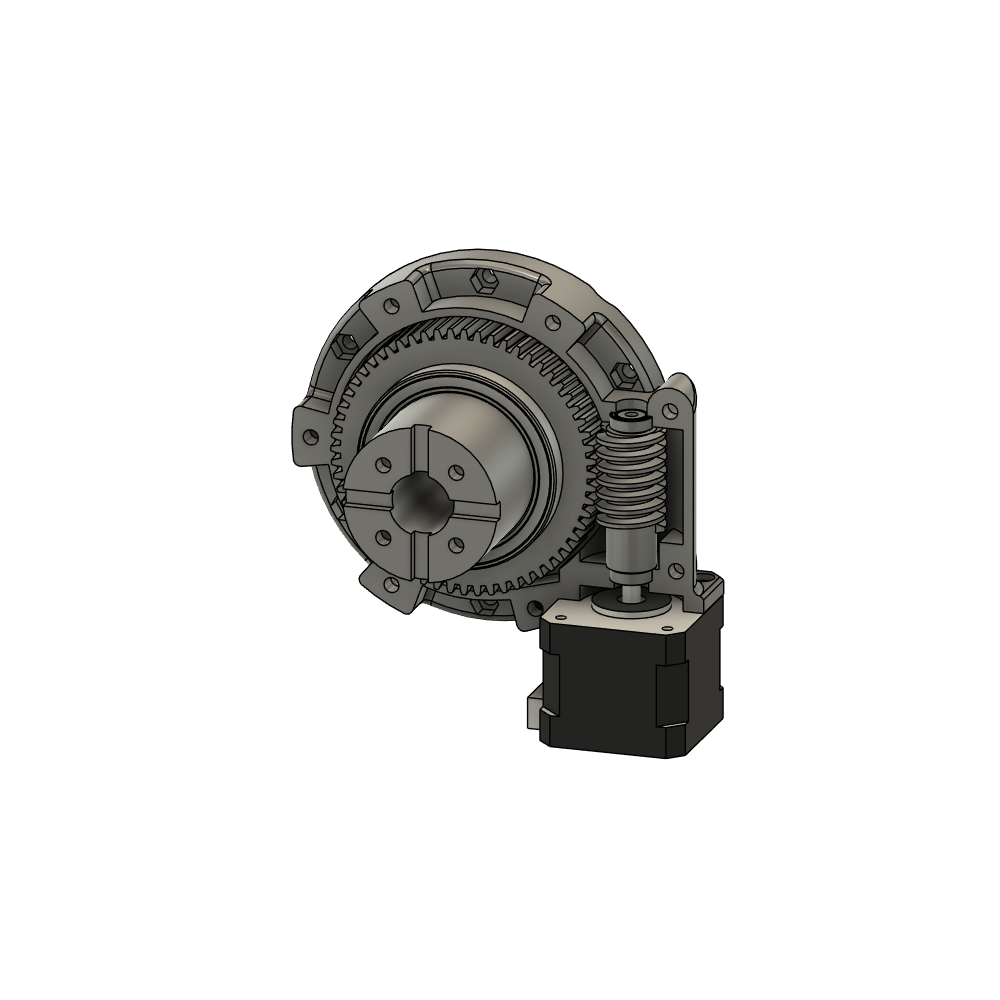
3-2. Main Actuator
 |  |
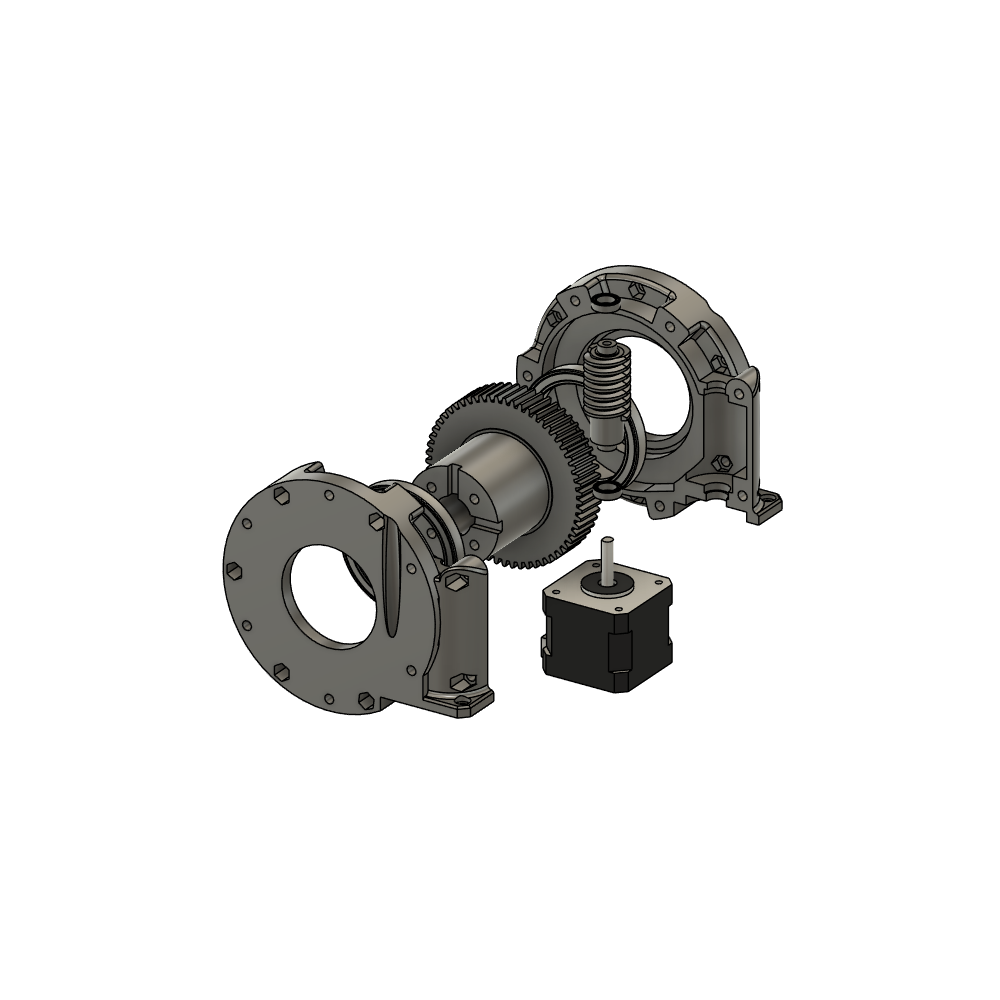 | 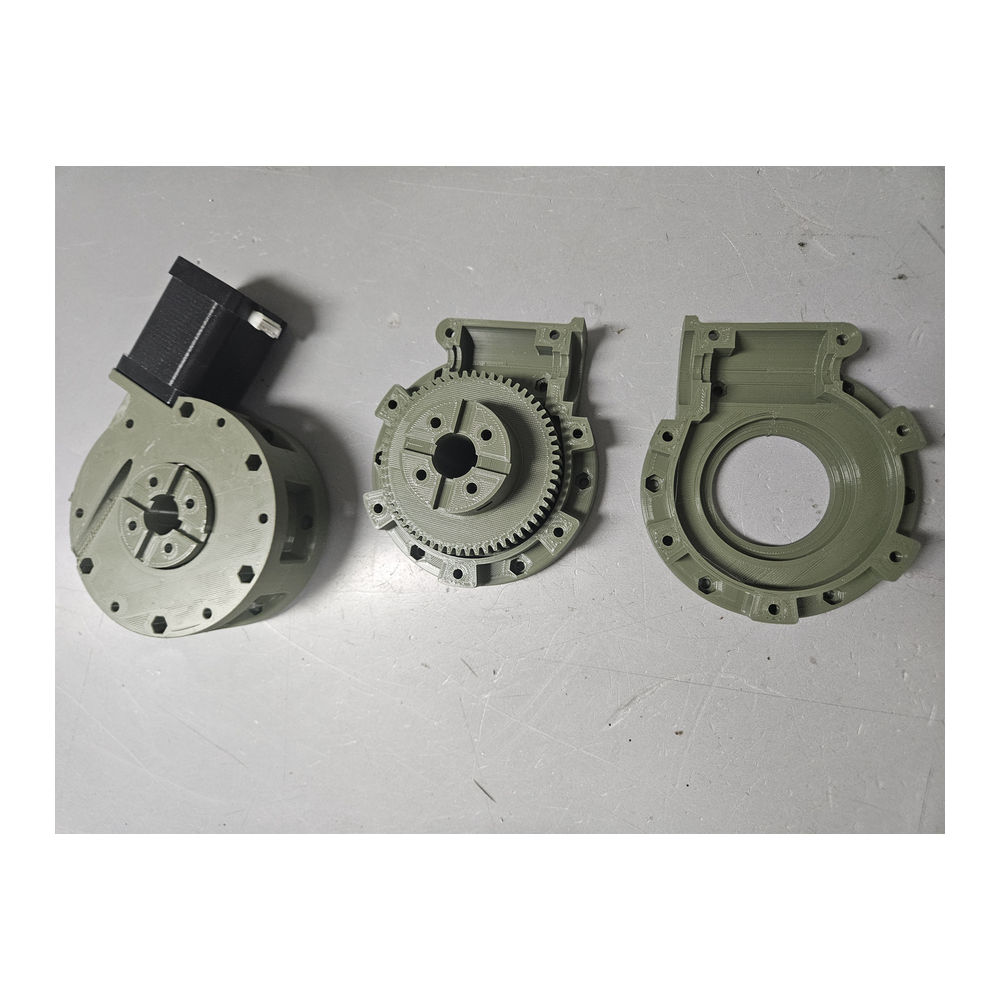 |
Figure 4.
<Non 3D printed Parts>
NEMA17 stepper motor
M3 x 5mm bolt
M3 hex nut
M4 x 15mm bolt
M4 hex nut
6809ZZ bearing
MR128ZZ bearing
3-3. 3D-Printed Azimuth Bearing
The entire frame and beads are 3D printed because of cost of bearing.
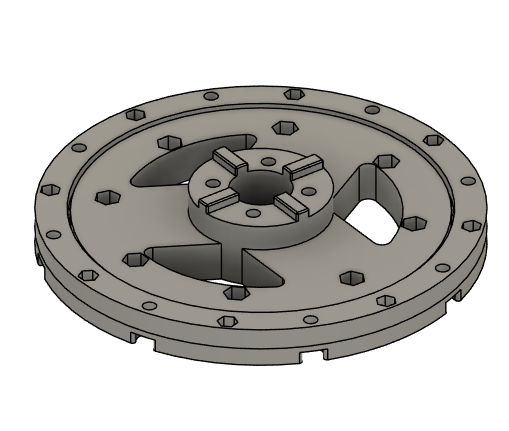
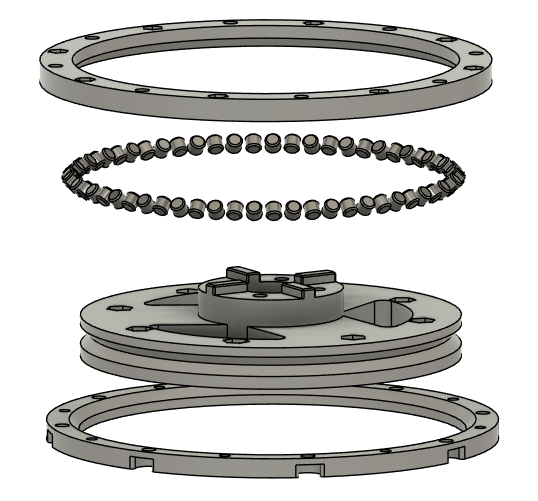
Figure 5.
<Non 3D printed parts>
M3 x 12mm bolt
M3 hex nut
M4 x 15mm bolt
M4 x 20mm bolt
M4 hex nut
3-4. Tripod
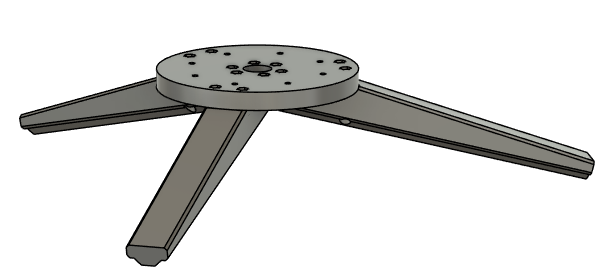
Figure 6.
<Non 3D printed parts>
M4 x 15mm bolt
M4 hex nut
4. Launcher
The launcher primarily consists of a feeder and an accelerator. An EOTS mount is located on the lower section of the assembly.
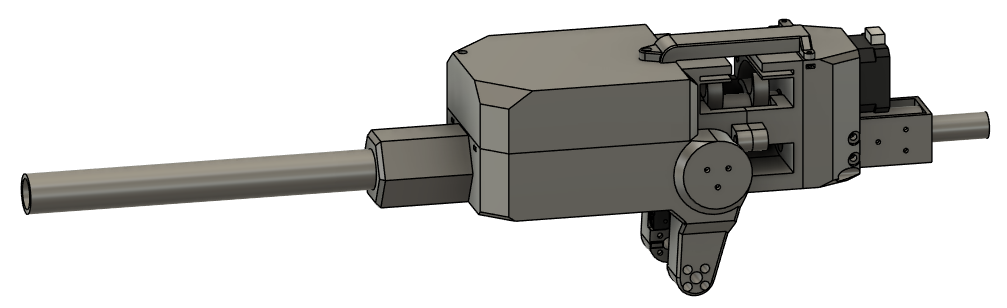
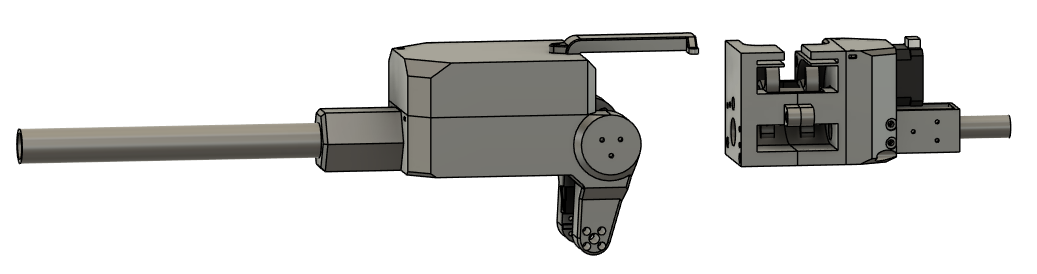
Figure 7.
4-1. Feeder
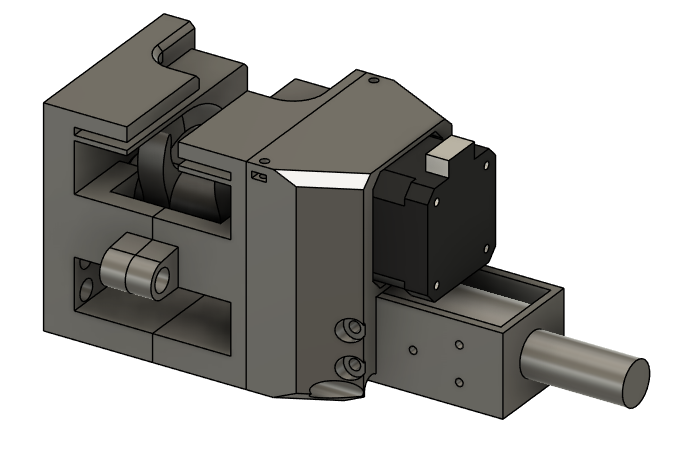
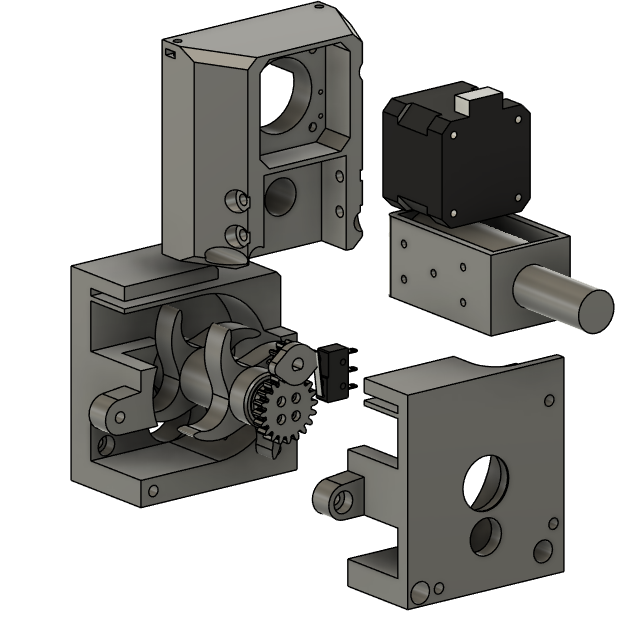
Figure 8.
<Non 3D printed parts>
NEMA17 stepper motor
35mm stroke 12v solenoid
M2 x 10mm bolt
M3 x 5mm bolt
M3 x 10mm bolt
M4 x 15mm bolt
M4 hex nuts
4-2. Accelerator
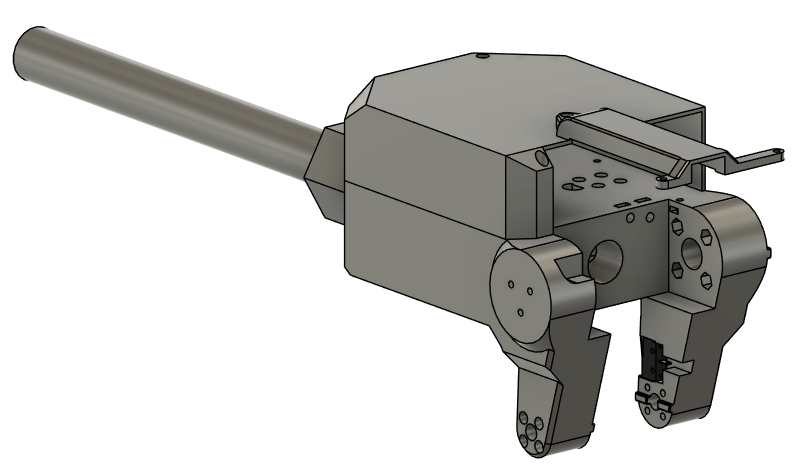
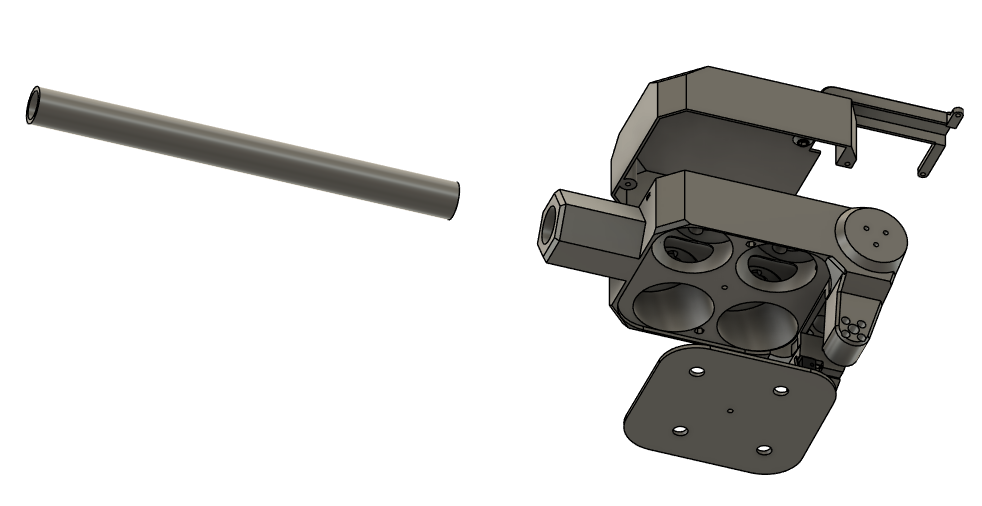
Figure 9.
<Non 3D printed parts>
2204 2300kv BLDC motor
OD 26mm ID 20mm pvc pipe
limit switch
M3 x 7mm bolt
M3 hex nut
M4 x 15mm bolt
M4 hex nut
5. EOTS
The EOTS features a cable-driven camera zoom mechanism and an adjustable rangefinder zero. It is mounted on a two-axis gimbal, and each axis can be calibrated using an individual limit switch.
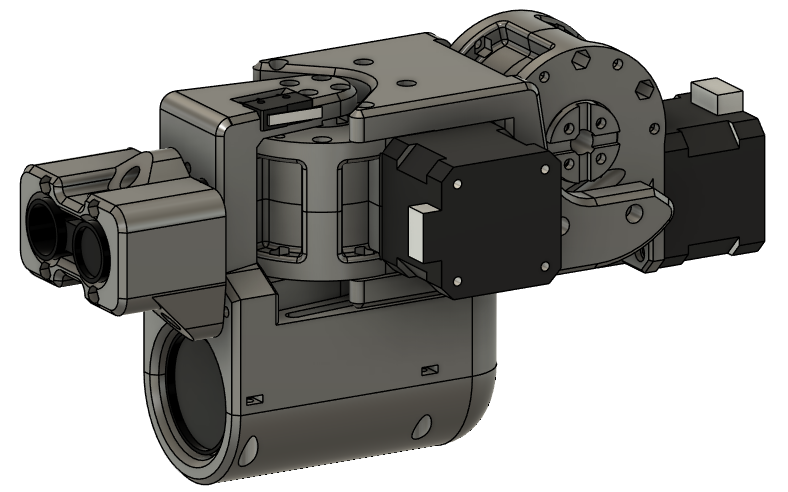
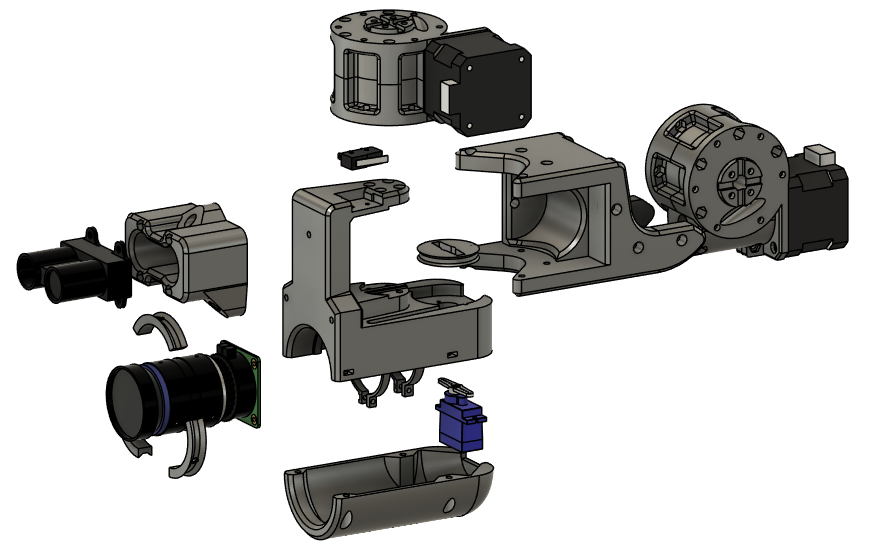
Figure 10.
5-1. EOTS Actuator
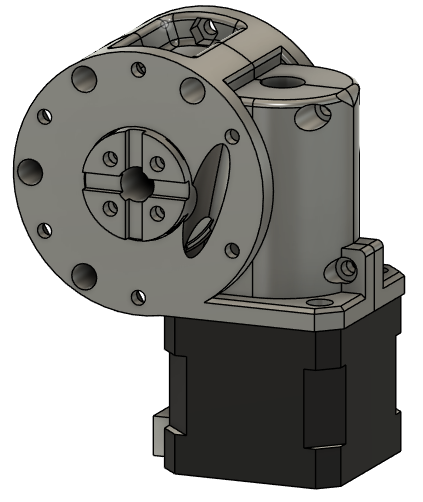
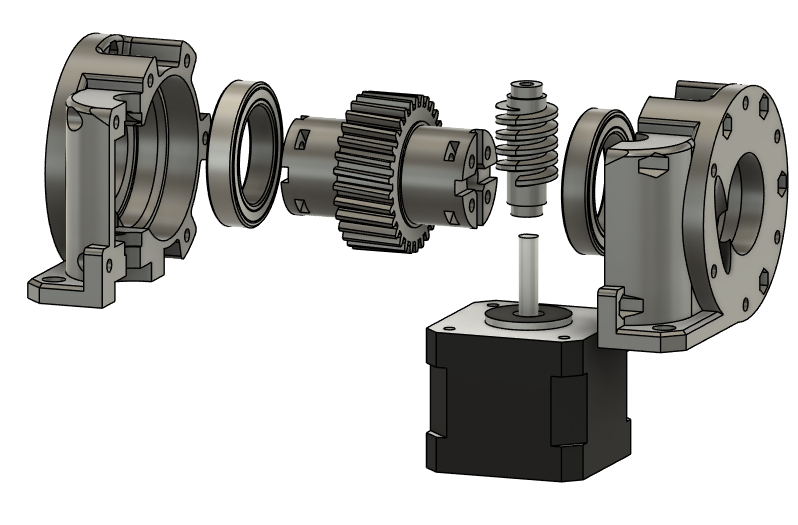
Figure 11.
<Non 3D printed parts>
M3 x 5mm bolt
M3 x 10mm bolt
M3 hex nut
MR128ZZ bearing
6805ZZ bearing
5-2. Camera Frame
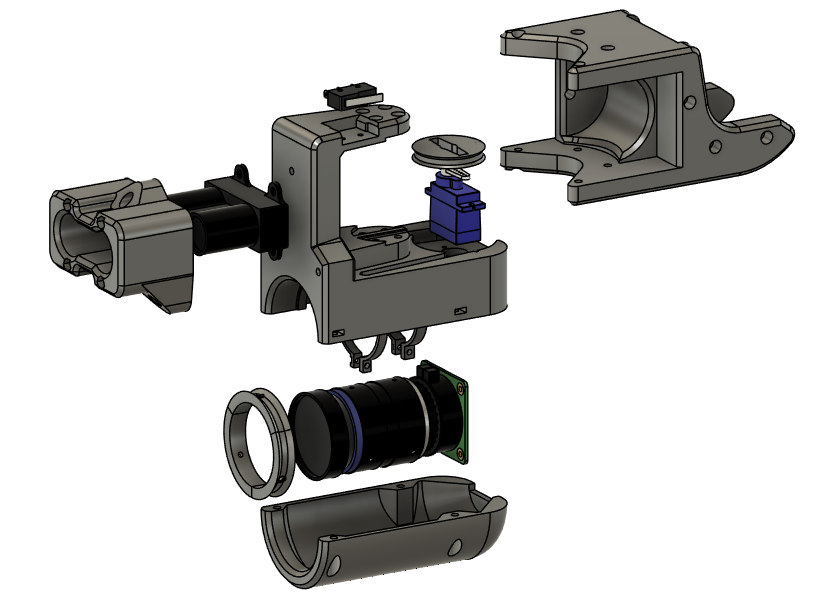
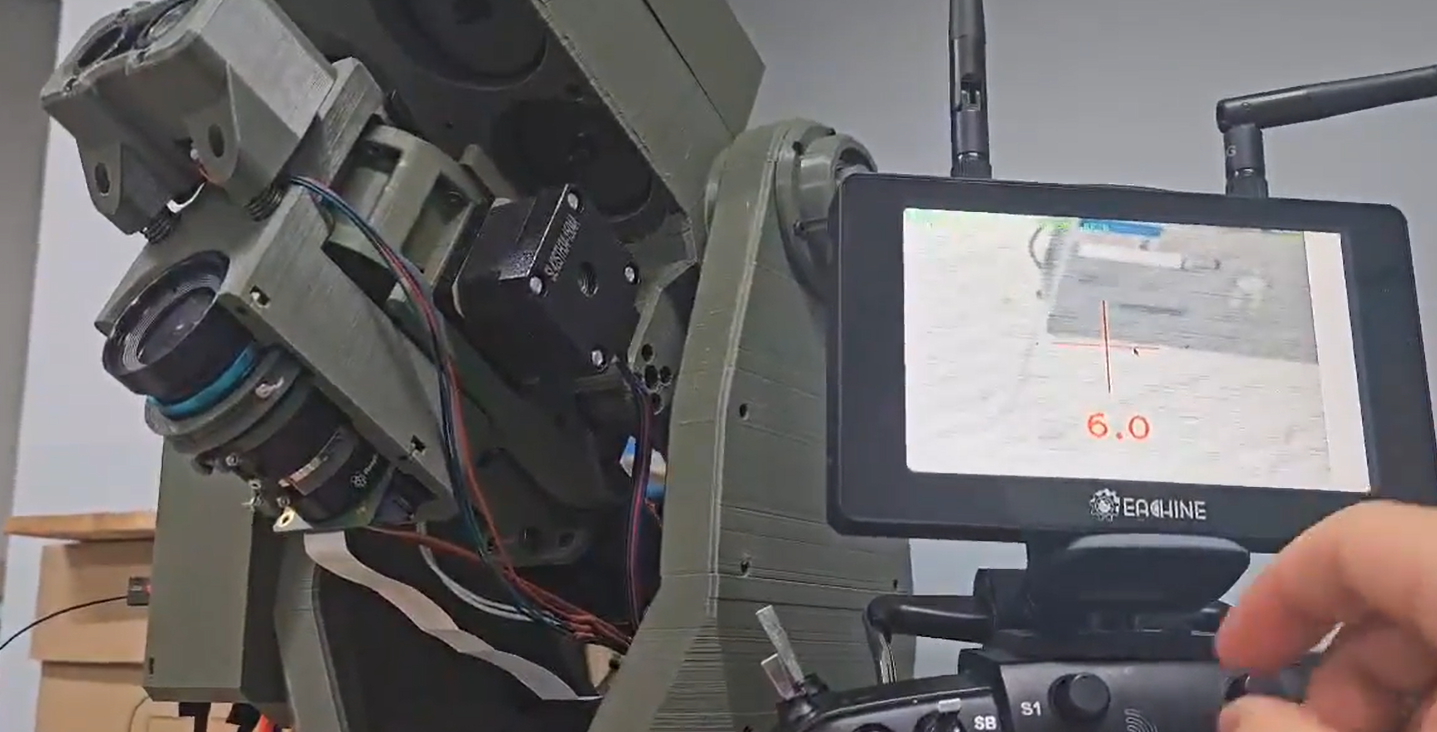
Figure 12.
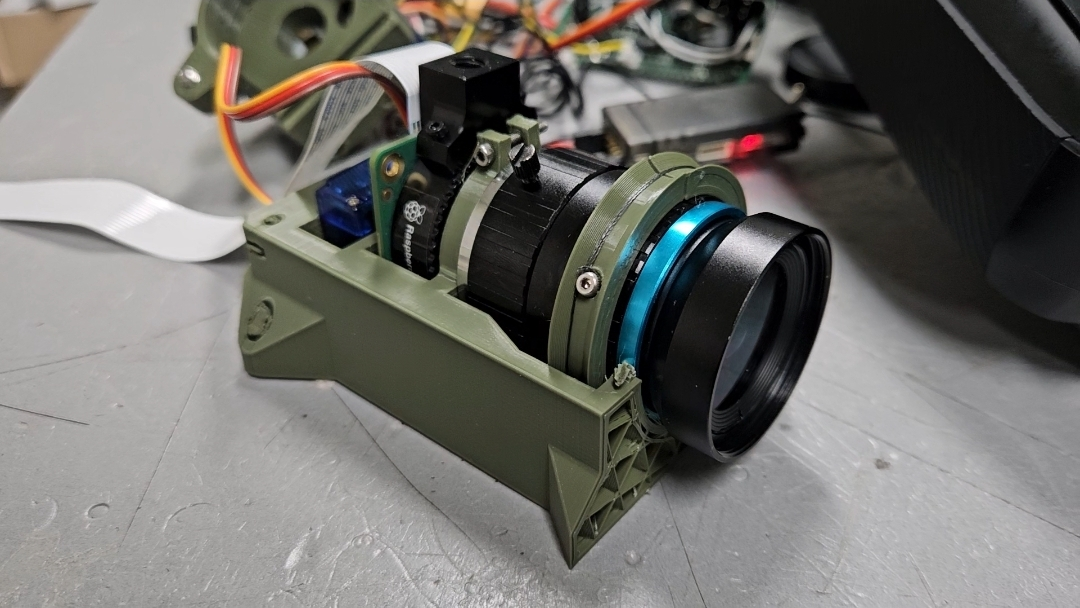
Figure 13.
<Non 3D printed parts>
sg90 servo motor
raspberry pi HQ camera
limit switch
M2 x 3mm bolt
M2 x 12mm bolt
M2 hex nut
M3 x 10mm bolt
M3 x 25mm bolt
M3 hex nut
6. Electronic Control
Unfortunately, most of the documentation related to the electronic control system has been lost. An Arduino was used to control the stepper motors and interpret PWM signals from the RC transmitter and receiver, while a Raspberry Pi 4 was used for image processing.
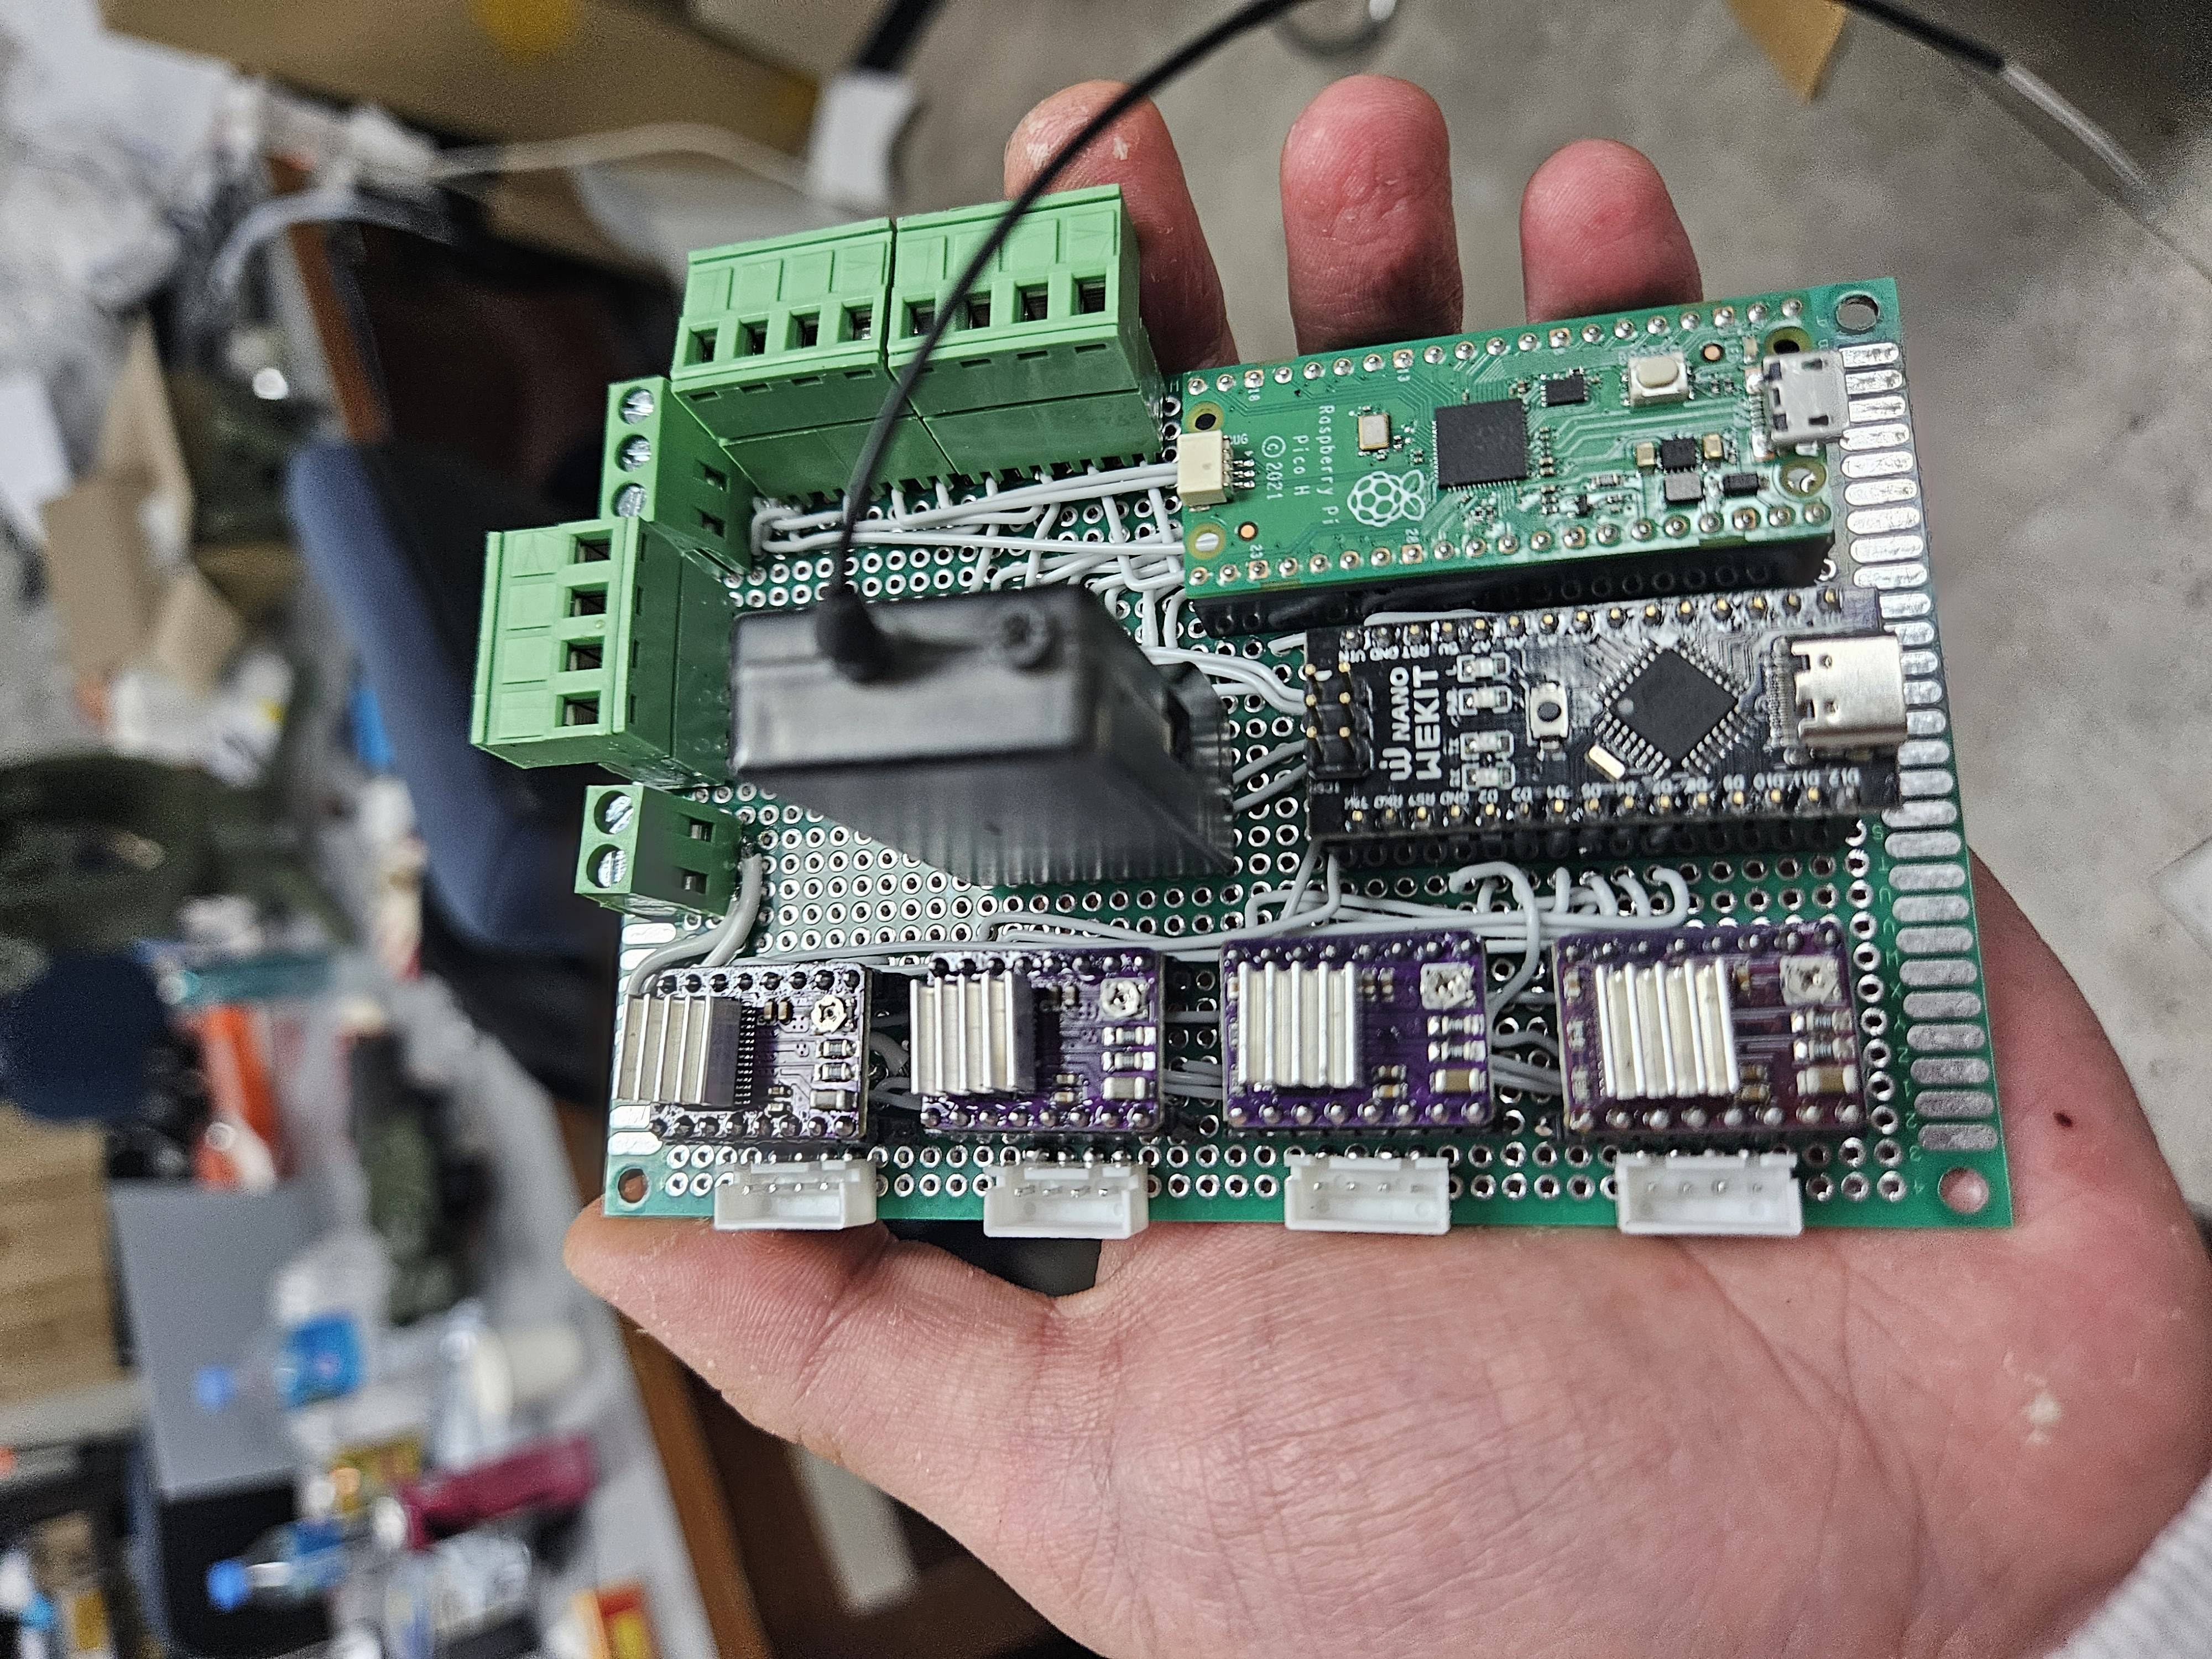
Figure 14.
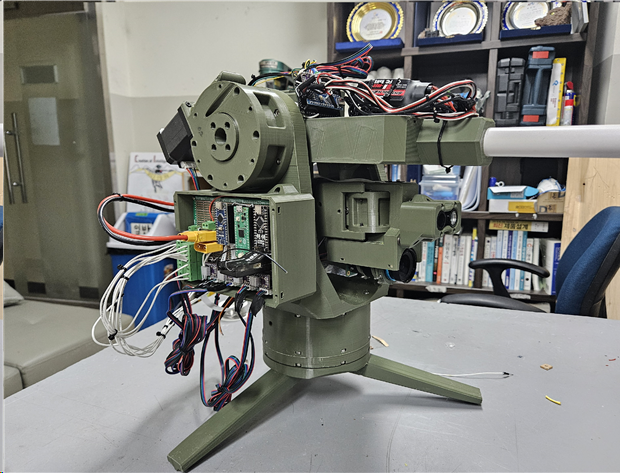
Figure 15.
Made by wildcard
github.com/wildcard1719 · wildcard1719@gmail.com